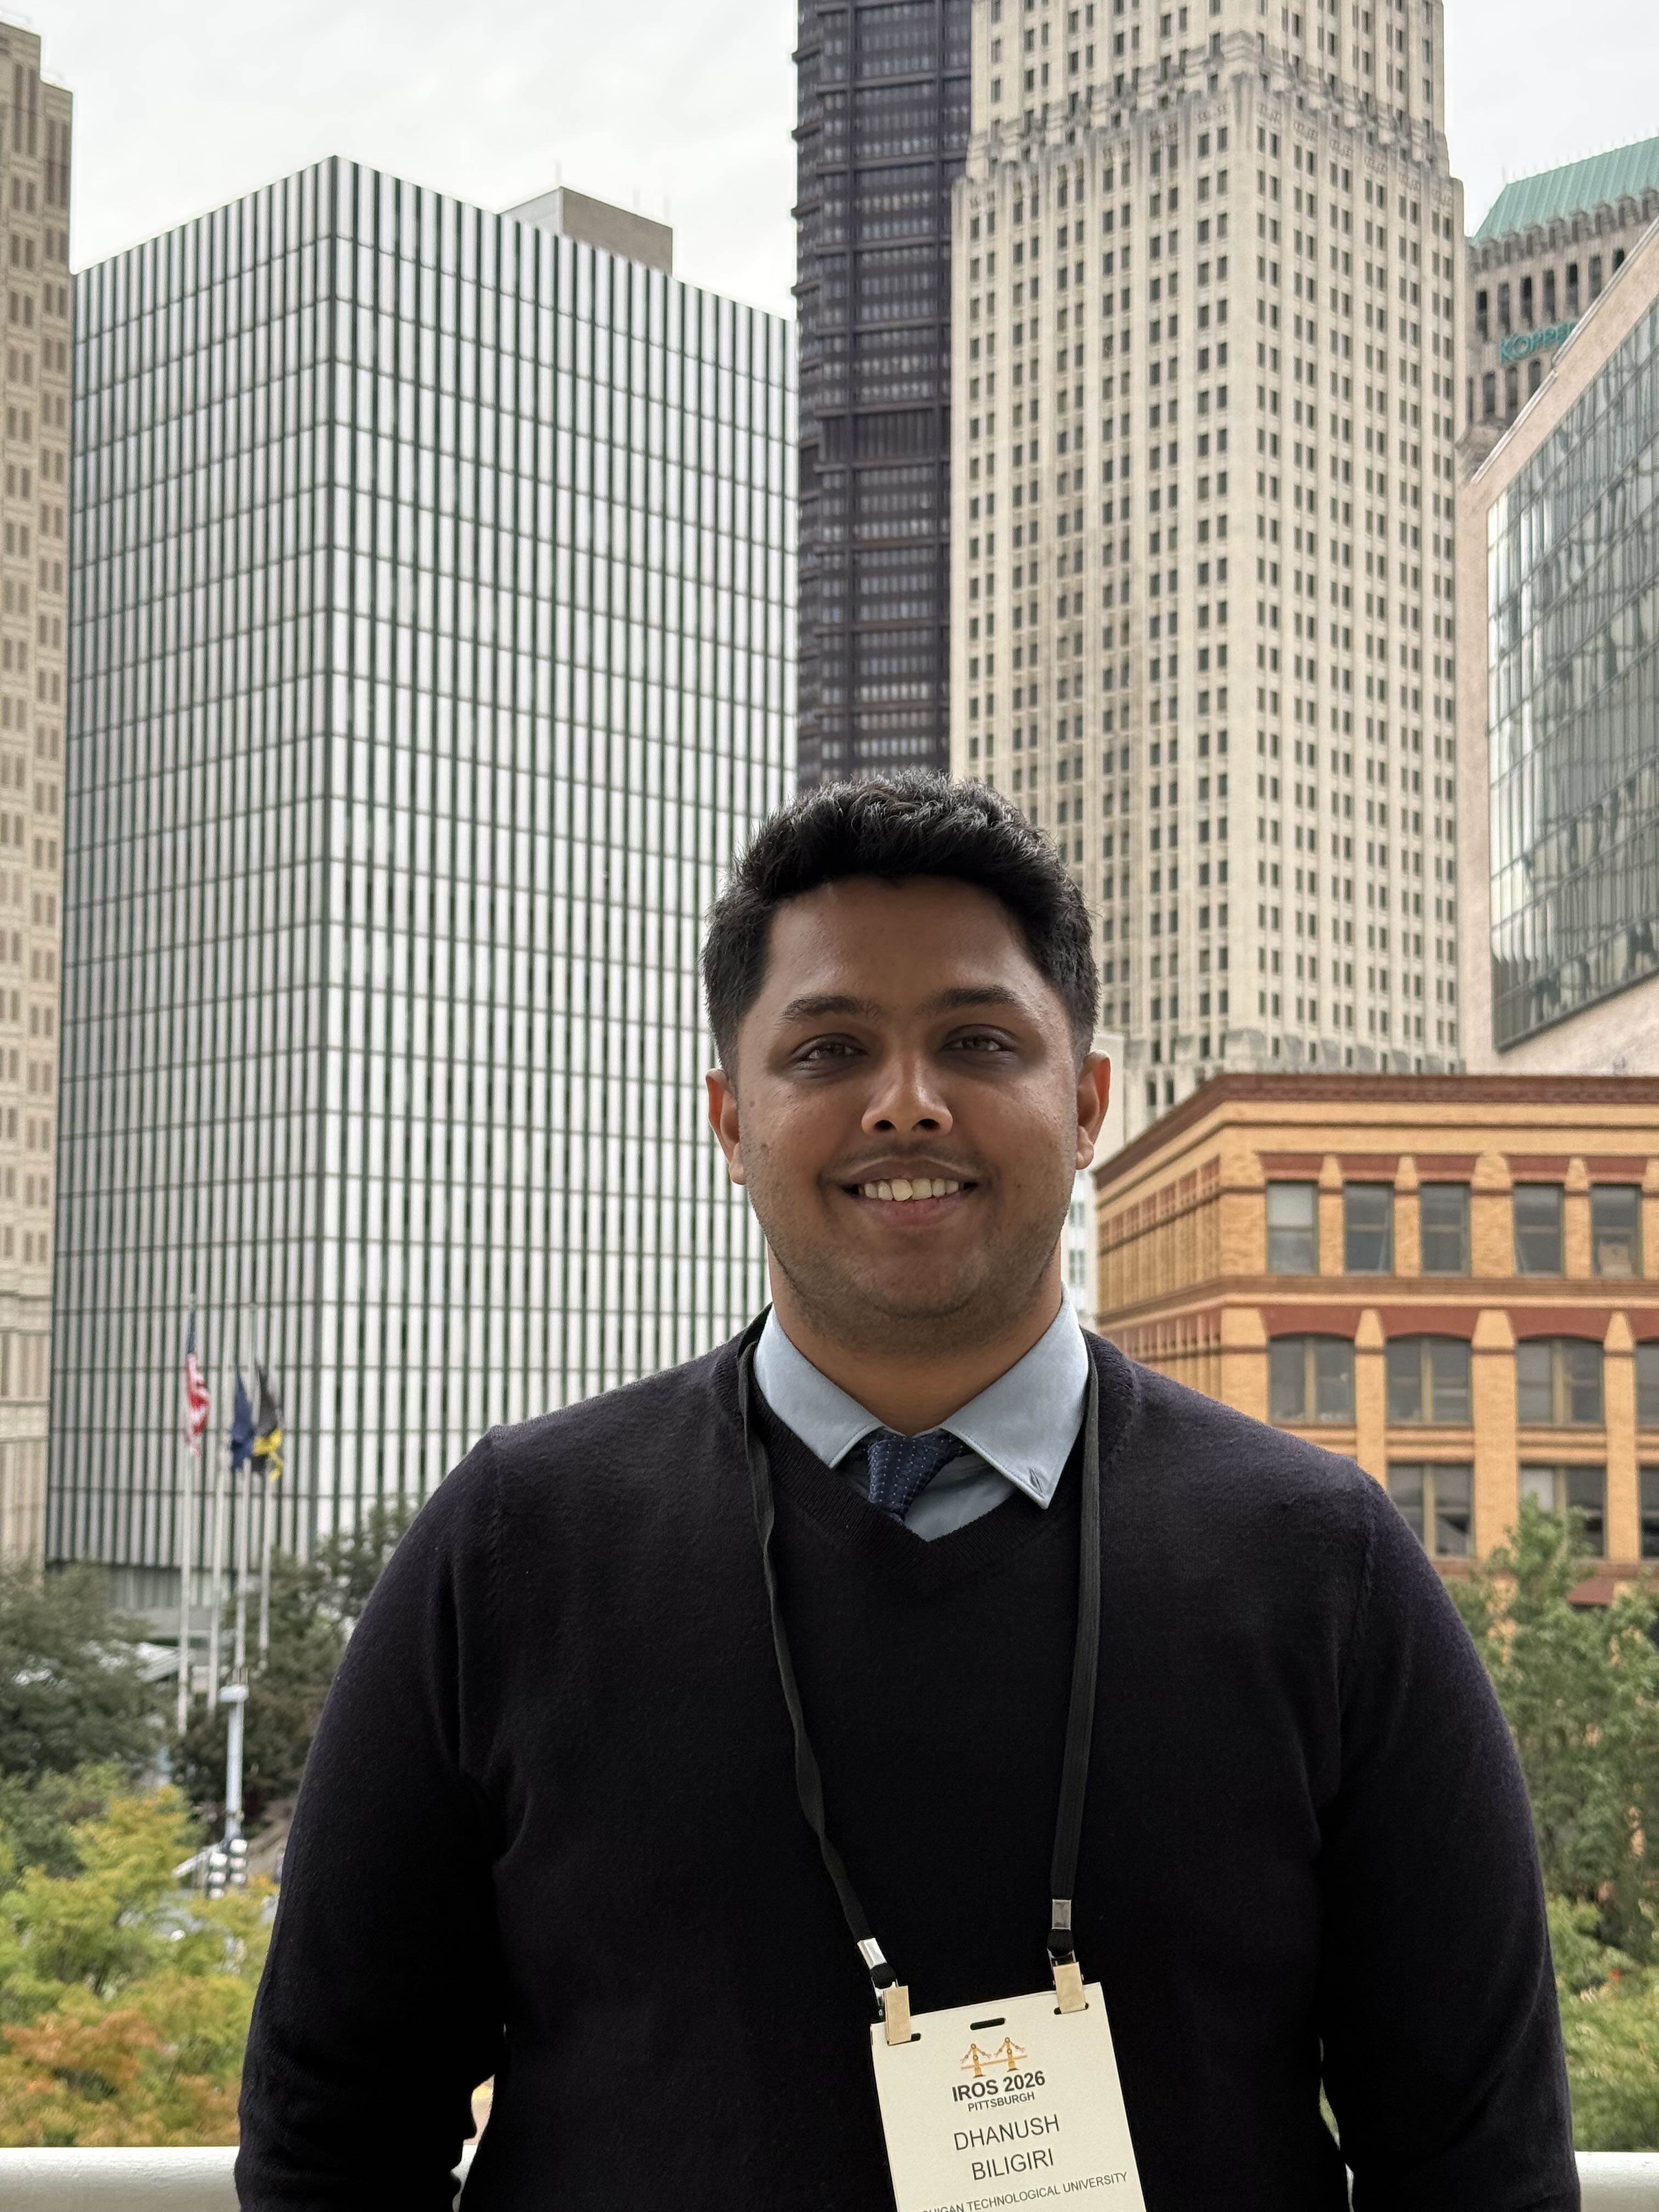
Dhanush Biligiri’s Portfolio
Hi! I’m a Ph.D. student in Electrical and Computer Engineering at Binghamton University, specializing in reinforcement learning, robotics, and control for legged and humanoid systems.
My work focuses on developing learning-based locomotion controllers that remain robust when robot dynamics, actuator capabilities, or operating conditions change. I am particularly interested in fault-tolerant locomotion, adaptive control, and reinforcement learning for bipedal and humanoid robots. My current research includes multi-fault-tolerant control for the Unitree G1 humanoid, energy-aware locomotion for bipedal robots, and studying how locomotion strategies emerge under different physical and environmental constraints.
I build and evaluate these systems primarily in MuJoCo and Isaac Lab, working across reinforcement learning, simulation, robot dynamics, control, and experimental analysis. My experience also includes machine learning, computer vision, scientific computing, and neural-network-based modeling.
I enjoy problems where algorithms have to interact with real physical constraints rather than only optimize a benchmark. I am especially interested in building robotic systems that can adapt, recover from failures, and continue performing useful tasks in uncertain environments.
Outside research, I enjoy basketball, running, golf, Formula 1, the Golden State Warriors, and Indian cricket.
News
Sep 25, 2025 — Jonathan Bara Award for Outstanding Graduate Teaching Assistant
Sep 02, 2025 — FractionalNet published in Nonlinear Dynamics
Jul 07, 2025 — Completed Ph.D. Qualifying Examination
Jun 20, 2025 — Undergraduate Research Symposium Evaluator
May 01, 2025 — Started Teaching EE3010
Recent Reads
Sep 27, 2026 — The Lucifer Effect, Philip Zimbardo
Sep 20, 2026 — Walk These Ways, Margolis et al.