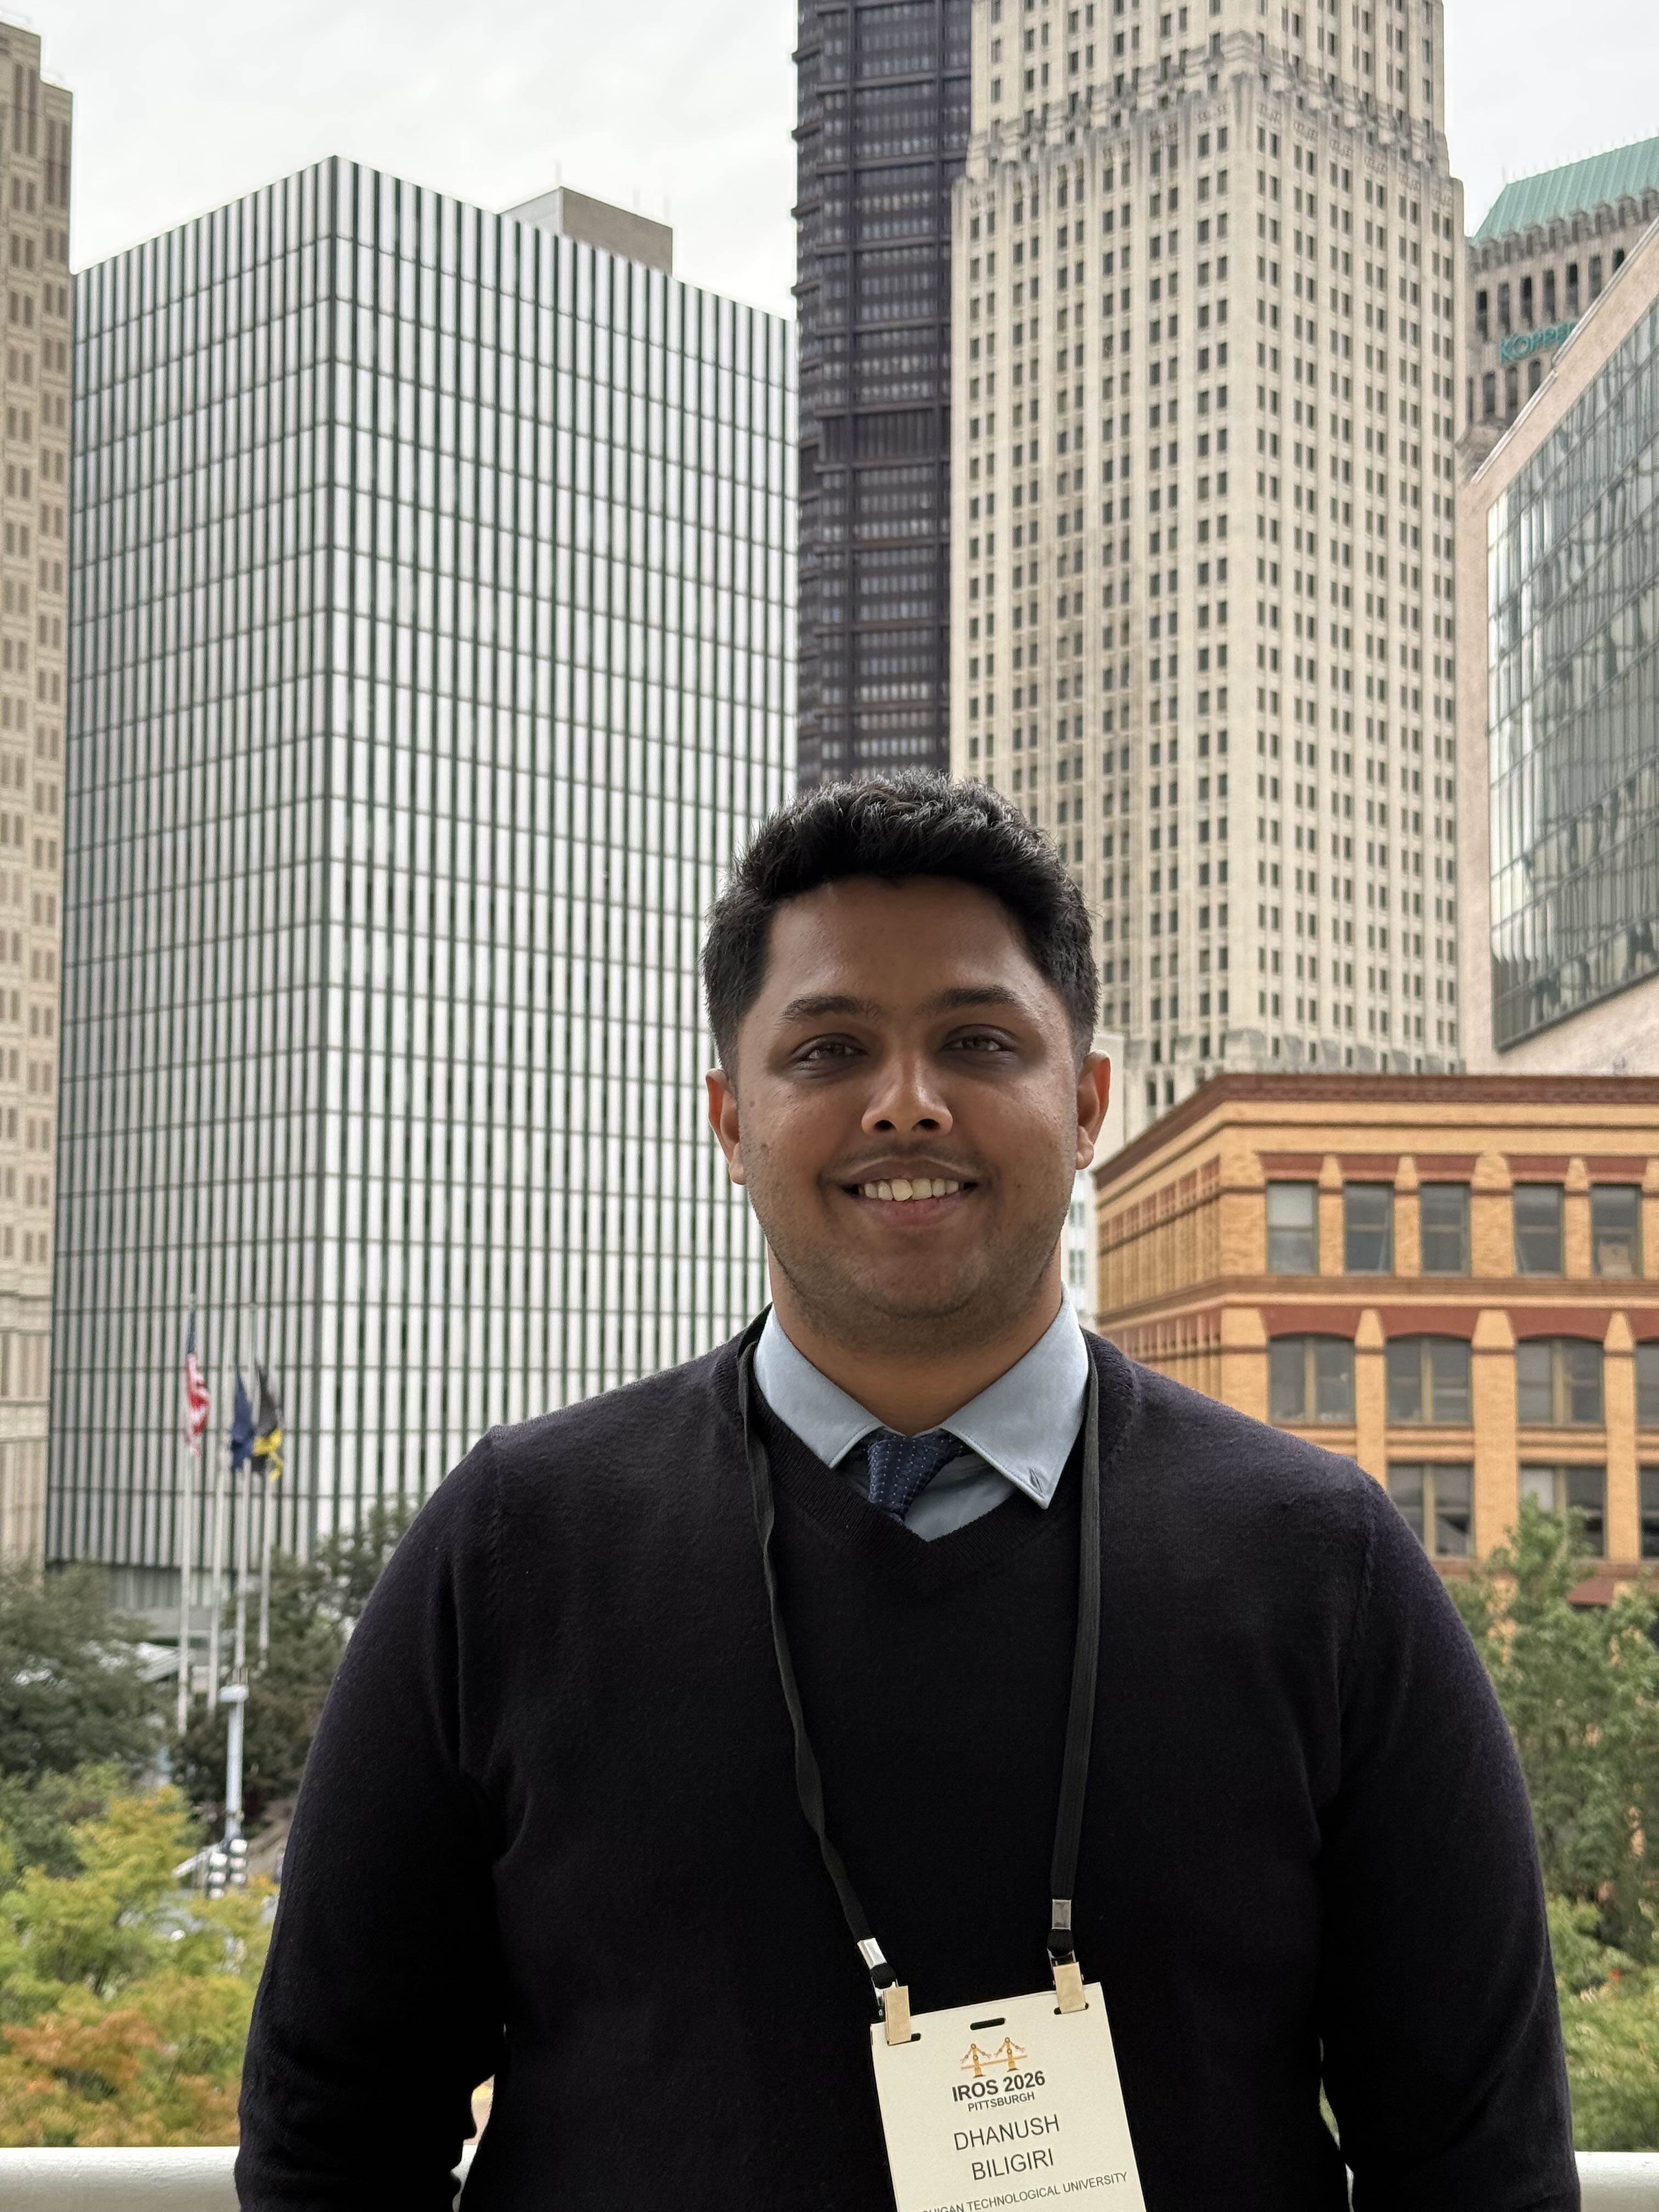
Doctoral student in Electrical and Computer Engineering at Binghamton University working on reinforcement learning, control, and learning-based locomotion for bipedal and humanoid robots.
This is a page not in the menu. You can use markdown in this page.